 Product
 Brand
 Articles
 Tools

How do Parking Sensors Work?

How do parking sensors work?
Most bumper-mounted parking sensors use ultrasonic time of flight. A transducer sends a short sound pulse above the range of human hearing, listens for the echo, and gives the control unit a round-trip travel time. The controller converts that time into an estimated distance and then changes the audible or visual warning as the vehicle moves closer to an obstacle.
The important qualification is that a parking sensor does not create a complete picture of the space around a vehicle. Target angle, size, height, material, weather, contamination, bumper damage, and the sensor's own transmit-to-receive recovery time can all change what is detected. A camera adds visual context, but it has its own blind areas and visibility limits. The safest approach is to use the available aids together with direct observation and mirrors.
1. How ultrasonic parking sensors measure distance
An ultrasonic transducer contains a piezoelectric element that converts an electrical burst into mechanical vibration. That vibration launches a short pressure wave through the air. When the wave reaches a sufficiently reflective object, part of its energy returns to the sensor as an echo.

The basic calculation is:
Distance = speed of sound x round-trip time / 2
The division by two matters because the measured time includes both the outward trip and the return trip. Texas Instruments gives 343 m/s as the speed of sound in dry air at 20 degrees C and notes that sound speed changes with temperature. Real systems therefore use calibration, temperature information, vehicle-specific thresholds, or a combination of these methods instead of treating 343 m/s as a constant under every condition.
The measurement cycle, step by step
Activation: The vehicle enables the relevant parking channels, commonly when reverse is selected or when the vehicle is moving at parking speed.
Transmit: The controller or local sensor electronics excite one transducer with a short ultrasonic burst.
Recovery: The transducer and analog front end need time to settle after the strong transmit pulse.
Listen: The receive path amplifies and filters returning echoes.
Detect: Signal processing compares echo features with calibrated thresholds and identifies credible returns.
Calculate: The controller converts time of flight into distance and associates the result with a sensor zone.
Warn: A buzzer, cluster, center display, haptic alert, or brake function responds according to the vehicle's design.
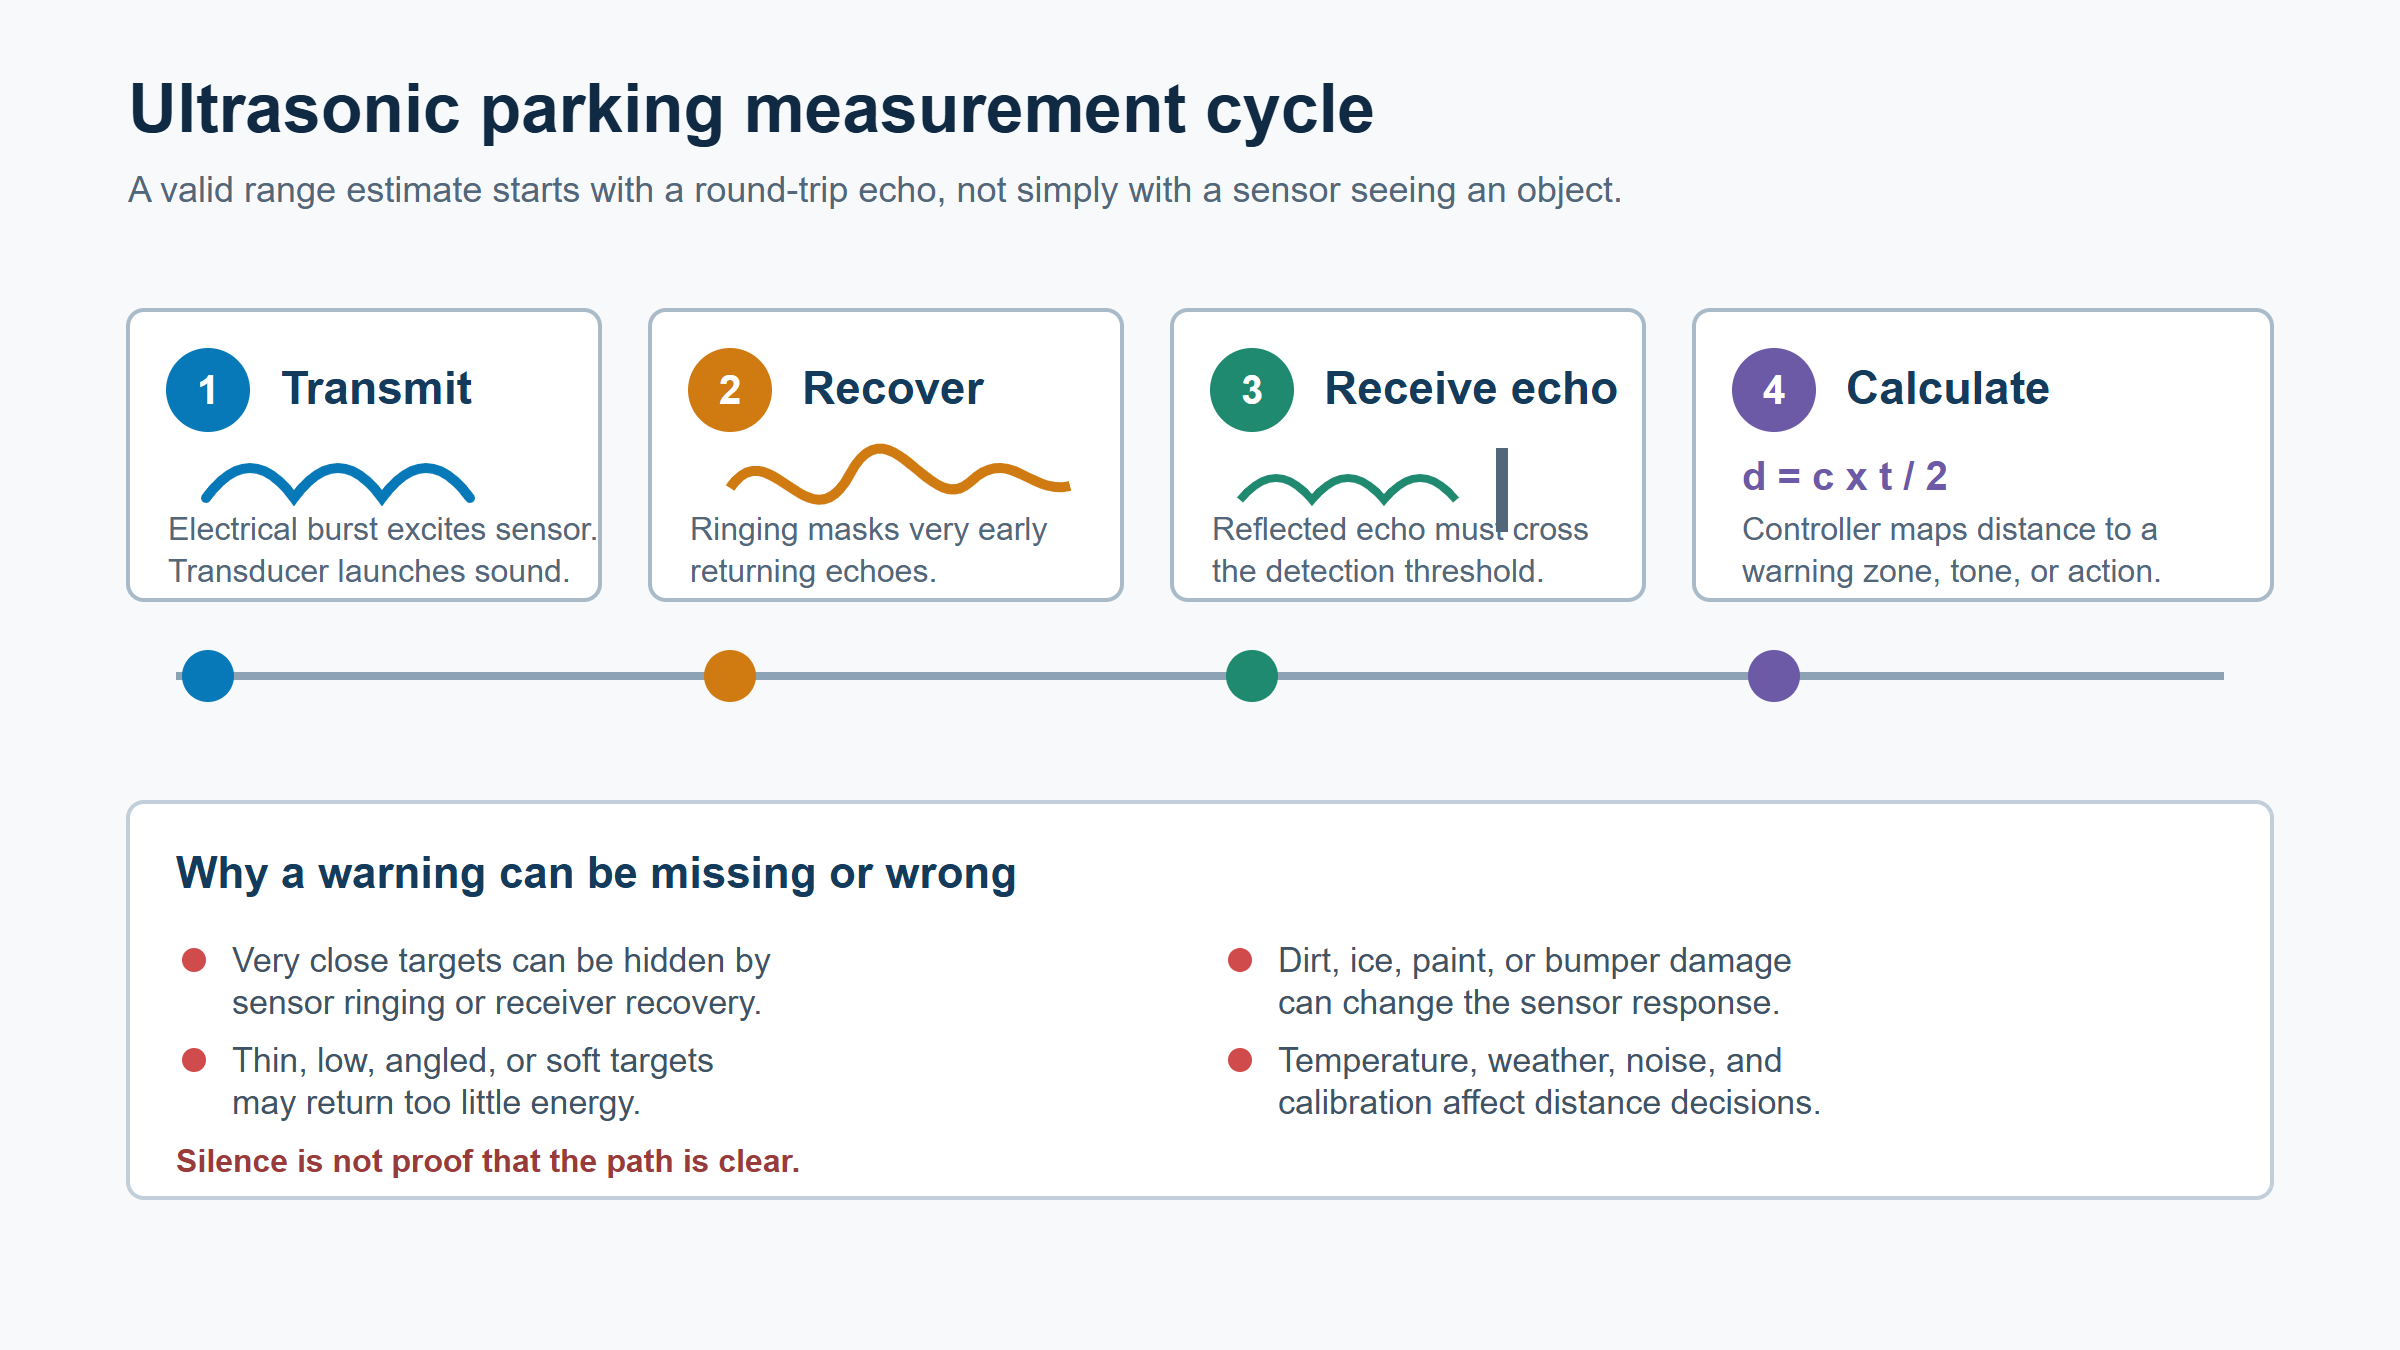
This sequence repeats rapidly while the function is active. Multi-sensor systems schedule transmissions so that an echo from one sensor is less likely to be mistaken for another sensor's return.
2. What is inside a parking sensor system?
A conventional ultrasonic parking aid is more than the round discs visible in the bumper. Its main blocks are the transducers, their driver and receive electronics, a controller, the vehicle network or wiring harness, and one or more driver interfaces.

| System block | What it does | What can go wrong |
|---|---|---|
| Ultrasonic transducer | Converts electrical energy to sound and returning sound to an electrical signal | Dirt, ice, excess paint, physical damage, poor mounting, or aging can weaken or distort the response |
| Driver and analog front end | Generates the transmit burst, protects the receive path, amplifies and filters echoes | Electrical faults, noise, water ingress, or incorrect component values can reduce sensitivity |
| Signal processing | Detects echoes and estimates time of flight, amplitude, and sometimes echo width | Thresholds that do not match the transducer, bumper, or environment can cause misses or false alerts |
| Parking ECU or domain controller | Coordinates sensors, combines zones, runs diagnostics, and sends warnings | Network, power, calibration, or software faults may disable the function |
| Buzzer and display | Converts distance zones into tones, bars, graphics, or messages | A muted alert, failed speaker, display issue, or misunderstood warning can hide useful information |

Texas Instruments' PGA460-Q1 is one example of the electronics used to explain this architecture. It integrates a transducer driver, analog receive chain, digital signal processing, communication interfaces, temperature monitoring, and diagnostics. It is an example, not a claim that every vehicle uses the same device or circuit topology.
3. Why a parking sensor has a minimum range
Immediately after transmission, a piezoelectric transducer continues vibrating. This ringing decay can be much stronger than an early echo. The receiver may also be recovering from the high-energy burst. During this interval, a very close object can be difficult to separate from the sensor's own response.

TI's ultrasonic park-assist note describes the design tradeoff directly: stronger or longer excitation can improve long-range echo strength, but it also extends ringing decay. The useful minimum distance therefore depends on the transducer, drive settings, mounting, receive chain, thresholds, target, and signal-processing design. It is not safe to assign one universal blind-zone distance to every vehicle.
Current product data illustrates that dependence. Bosch's ultrasonic-sensor one-page specification lists a 15 cm minimum range and a 5.5 m maximum range for a defined 7.5 cm diameter pole target. Those are target-qualified specifications for that Bosch sensor, not default values for every parking aid. The owner's manual for the specific vehicle remains the correct source for operating zones and alert thresholds.
4. What parking sensors can miss
Ultrasonic sensing works best when enough acoustic energy returns to the receiver. A broad, rigid surface facing the sensor normally produces a stronger return than a thin, soft, low, sharply angled, or irregular target.
| Situation | Why detection may be weak or misleading | Driver response |
|---|---|---|
| Thin post, cable, chain, or narrow edge | Small reflecting area can return too little energy | Check visually and do not use silence as proof of clearance |
| Low curb or object near the ground | Target can fall below the sensor's effective field or enter a close blind area | Use the camera and direct observation; stop if uncertain |
| Sloped or angled surface | The echo may be reflected away from the receiver | Approach slowly and verify with another view |
| Soft or sound-absorbing material | Foam, soft clothing, or powdery snow can absorb acoustic energy | Treat weak or absent warning as inconclusive |
| Drop-off or empty space | A conventional obstacle sensor detects reflected objects; it does not guarantee ground continuity | Inspect the ground and edge directly |
| Dirt, snow, ice, stickers, or accessories | The sensor face or detection zone can be blocked or altered | Clean the sensor gently and remove the obstruction |
| Damaged or misaligned bumper | Sensor orientation and calibrated field can change | Have the system inspected after impact or bumper repair |
| Heavy rain, snow, spray, or external ultrasonic noise | Propagation, reflections, and threshold decisions can be disturbed | Expect reduced performance or false alerts and rely on direct observation |
Ford's parking-aid precautions explicitly warn that small or moving objects, especially those close to the ground, may not be detected. The manual also lists sound-absorbing surfaces, severe weather, blocked sensors, bumper misalignment, and add-on devices as causes of reduced performance or false alerts. These are useful general examples, but vehicle-specific warnings always take precedence.
5. How to read the warnings
Most systems divide distance into zones rather than presenting laboratory-grade measurement data. An intermittent tone commonly becomes faster as the estimated distance decreases, while a continuous tone marks a close warning zone. Visual systems may identify the left, center, or right sensor zone and may overlay colored bands near a vehicle graphic or camera image.
Do not assume the last displayed number is the exact bumper-to-object clearance. The system may quantize distance, hold a previous detection, suppress an uncertain echo, or stop resolving an object inside its minimum range. Alert logic and thresholds vary by manufacturer and model.
Three warning patterns deserve attention:
No warning after startup: The system may be switched off, unavailable at the current speed or gear, blocked, or reporting a stored fault.
A constant warning with no obvious obstacle: Check for dirt, ice, moisture, a tow hitch, bike rack, license-plate frame, bumper damage, or an object very close to the sensor.
One zone behaves differently: Compare sensor cleanliness and mounting. A diagnostic scan or service inspection may be needed if the symptom remains.
6. Parking sensors vs. a backup camera
Parking sensors and cameras answer different questions. Ultrasonic sensors estimate proximity within calibrated zones. A camera shows visual context: what the object is, where markings are, and how the vehicle is aligned. Neither proves that every hazard is visible.

| Capability | Ultrasonic parking sensors | Backup camera |
|---|---|---|
| Primary output | Distance-zone warning, often audible and visual | Live image behind or around the vehicle |
| Useful strength | Works without requiring continuous attention to a screen; good for close reflective obstacles in its field | Shows object identity, parking lines, ground features, and vehicle alignment |
| Important limitation | Can miss low, thin, angled, soft, very close, or out-of-field targets | Lens contamination, darkness, glare, distortion, display attention, and camera blind areas can reduce usefulness |
| Best role | Proximity cue | Visual confirmation and context |
| Safe practice | Combine the alert with mirrors and a direct check | Combine the image with mirrors, direct observation, and available proximity alerts |
In the United States, NHTSA states that backup cameras have been required on all new vehicles since May 2018. The agency also emphasizes that a backup camera is not a replacement for mirrors or turning around to look. A regulatory camera requirement should not be interpreted as proof that a particular vehicle also includes ultrasonic parking sensors, surround view, rear automatic braking, or rear cross-traffic warning.
7. Why modern vehicles combine sensing methods
Sensor fusion uses complementary information rather than expecting one sensor type to solve every parking problem. Bosch describes parking systems that combine near-range cameras and ultrasonic sensors in a central control unit. The camera contributes scene and marking information; ultrasound contributes close-range echo measurements. Depending on the vehicle, the fused result may support surround-view displays, automated steering, remote parking, or low-speed braking.
These feature names are not interchangeable:
Parking aid: Warns about detected obstacles; the driver remains responsible for the maneuver.
Surround-view camera: Combines several camera images to provide multiple views or a synthesized overhead view.
Parking assist: May steer the vehicle while the driver controls other parts of the maneuver, depending on the implementation.
Remote or automated parking: Can control more of the maneuver under defined conditions, but supervision and operating limits remain vehicle-specific.
Rear cross-traffic warning: Warns about potential crossing conflicts while reversing, including conflicts that may be outside the backup camera's view.
Rear automatic braking: May apply the brakes when the system predicts an imminent reversing collision.
Read the owner's manual before relying on any of these functions. Similar marketing names can conceal large differences in sensor set, speed range, driver responsibility, and stopping behavior.
8. Installation, calibration, and maintenance
Factory systems are designed around a particular bumper material, sensor position, orientation, paint thickness, wiring architecture, and software calibration. A sensor that physically fits the hole may still be the wrong service part for that vehicle.

For reliable operation:
Keep each sensor face free of dirt, wax buildup, snow, and ice. Use a soft cleaning method; do not scrape the membrane with a sharp object.
Inspect the bumper after an impact, repaint, wrap, accessory installation, or sensor replacement. Position and surface treatment can affect the field of view.
Check the vehicle manual before adding a tow hitch, bike rack, spare-wheel carrier, license-plate bracket, or bumper protector near a sensor.
Match the complete vehicle-approved part number and connector. Confirm whether coding, calibration, or a diagnostic routine is required.
Treat a persistent fault message, missing zone, or unexplained continuous tone as a diagnostic problem rather than simply increasing the audio volume or replacing random parts.
Aftermarket kits can add useful proximity information to an older vehicle, but their performance depends heavily on installation geometry and calibration. Before drilling a bumper, verify sensor height, spacing, orientation, bumper reinforcement clearance, electrical compatibility, display location, sealing, and how a trailer or accessory will affect the detection zone. Professional installation is appropriate when vehicle wiring, bodywork, safety functions, or network coding is involved.
9. Practical parking checklist
Walk around the vehicle when the area is uncertain, especially where children, pets, low objects, or drop-offs may be present.
Clean the sensors and camera before relying on them in snow, mud, or heavy spray.
Move at parking speed and keep the brake covered.
Scan mirrors, windows, and the camera instead of fixing attention on one display.
Treat a warning as a reason to slow or stop, but never treat silence as proof that the path is clear.
Stop immediately if sensor information conflicts with what you can see.
Parking technology is most useful as a set of independent clues. Audio proximity, camera context, mirrors, direct observation, and cautious speed reinforce one another; none should be promoted as a substitute for attentive control.
10. FAQ
Do parking sensors use radar?
Most round bumper parking sensors are ultrasonic transducers, not radar. Some vehicles also use radar and cameras for other driver-assistance functions, so the complete sensor set depends on the model.
What frequency do parking sensors use?
Automotive ultrasonic systems operate above the range of human hearing, but the exact transducer frequency is a design parameter. Do not assume one frequency or sensor is interchangeable with another; match the vehicle specification and complete part number.
Why does a parking sensor beep when nothing is there?
Dirt, ice, water, bumper damage, a tow hitch or rack, an object inside the very close zone, external interference, or a sensor fault can cause false or continuous alerts. Clean and inspect the sensor area first, then use vehicle diagnostics if the problem remains.
Can parking sensors detect people?
They may detect a person when enough sound is reflected within the sensor field, but they are not reliable person detectors. Small, moving, low, angled, or sound-absorbing targets can be missed. Always inspect the area directly.
Do parking sensors work in rain and snow?
They may continue operating, but rain, snow, spray, ice, and contamination can reduce performance or produce false alerts. Keep the sensor faces clean and follow the vehicle manual's weather limitations.
Are parking sensors better than a backup camera?
They provide different information. Sensors give proximity cues without requiring a continuous look at a screen, while a camera provides visual context. A combined system is more informative, but the driver must still use mirrors and direct observation.
11. References
Related Utmel resources
 UTMEL

We are the professional distributor of electronic components, providing a large variety of products to save you a lot of time, effort, and cost with our efficient self-customized service. careful order preparation fast delivery service
Does Halfords fit parking sensors?
If you are unsure which is the best rear parking sensor to have fitted to your car, just call into your local Halfords store and one of our team will be on hand to advise you. We can even arrange to have your parking sensor fitted.
How does parking sensor work?
The Ultrasonic sensors – just like bats – use high-frequency sound waves to detect objects. These sensors emit sound pulses that reflect off of nearby objects. A receiver detects the reflected waves and calculates the distance from your vehicle to the object.
How much does it cost to install parking sensors?
At the cheaper end of the scale, you could buy a DIY parking sensor kit and get it fitted by a professional. If you go down this route, you can expect to pay between £65 and £150 in labour. Alternatively, you could ask a professional to supply and install the sensors for you from scratch.
Are parking sensors easy to fit?
The simple answer is yes, since many manufacturers have developed clever ways to enable quick, seamless and discreet installation of the parking sensor components to virtually all vehicles.
How do I know if my car has a parking sensor?
Most cars featuring parking sensors will have these on the rear bumper, with some also having them on the front. Some will even give you a visual display on the infotainment system as well.
 The Key Role of Electronic Components in IoT DevicesUTMEL01 September 20236071
The article discusses the pivotal role of electronic components in Internet of Things (IoT) devices. IoT devices work by capturing real-world data using sensors, processing it through a microcontroller, and then sending it to the cloud for further analysis.
Read More Accelerometer Sensors Guide: Working Principle, Circuit Design, Specifications, and ApplicationsUTMEL25 June 2026681
A practical accelerometer sensor guide covering working principles, MEMS and piezoelectric types, datasheet specifications, circuit design, mounting, applications, and selection.
Read More 2026 ADAS Sensors: Supply Outlook and Alternative SourcingUTMEL18 July 2026871
Automotive cleanroom assembly integrating advanced driver assistance systems. The automotive industry faces a structural semiconductor deficit in 2026, driven not by pandemic-era demand shocks but by AI data centers absorbing global foundry capacity on legacy nodes (40nm-90nm) where 95% of automotive-grade components are manufactured. Video demonstrations of these systems show a "machine view" overlay with red crosshairs tracking pedestrian movement and sudden cut-ins before traditional collision thresholds are triggered.
Read More Magnetic Sensors for Position Detection: Hall Effect vs. AMR vs. TMR Engineering GuideUTMEL21 August 2026367
This guide compares Hall effect, AMR, and TMR magnetic sensors for position detection in motor control and robotics. It explains their physical principles, key performance metrics, and selection criteria. Hall effect suits low-cost commutation, AMR offers high-speed angle sensing, and TMR provides maximum precision and low power, with practical integration advice.
Read More Temperature Sensor Types Comparison: Thermocouple, RTD, and Semiconductor IC Selection GuideUTMEL17 August 2026281
This comprehensive selection guide compares thermocouples, platinum RTDs, and semiconductor ICs across measurement range, accuracy limits, and signal conditioning complexity. It covers fundamental operating physics, mathematical transfer functions, lead-wire compensation topologies, and power budgets. Engineers will find practical design checklists, benchtop multimeter diagnostic techniques, and an architectural decision workflow to optimize system performance and bill-of-materials cost.
Read More
Subscribe to Utmel !